Shaoxiong (Shawn) Wang

I'm a Member of Technical Staff at Tacta. I received my Ph.D. degree from the Computer Science and Artificial Intelligence Laboratory (CSAIL), MIT. I was advised by Edward H. Adelson, and also worked closely with Alberto Rodriguez. During my Ph.D., I worked with Roberto Calandra at Facebook AI Research. I obtained my bachelor's degree from the Department of Computer Science and Technology, Tsinghua University, where I worked with Jie Tang in the Knowledge Engineering Group.

wsxiong [at] gmail (dot) com
CV  /  Scholar  /  Github

profile photo

Industrial Projects

Dexterous Opening and Closing of an AirPods Case
Tacta Systems

A contact-rich dexterous manipulation policy trained with reinforcement learning. Touch feedback makes training more efficient, providing contact information that is challenging to obtain from vision alone.

Tight Packing for Automated Truck Loading
Dexterity

A transformer-based learned policy tightly packs boxes into slots, closing gaps between boxes to maximize trailer fill. Force feedback enables compliant, contact-rich box handling, detecting contact with walls, floor, and neighboring boxes during placement.

Publications

During my Ph.D., I studied tactile perception & manipulation, computer vision, and machine learning. Some papers are highlighted. * and † indicate equal contribution.

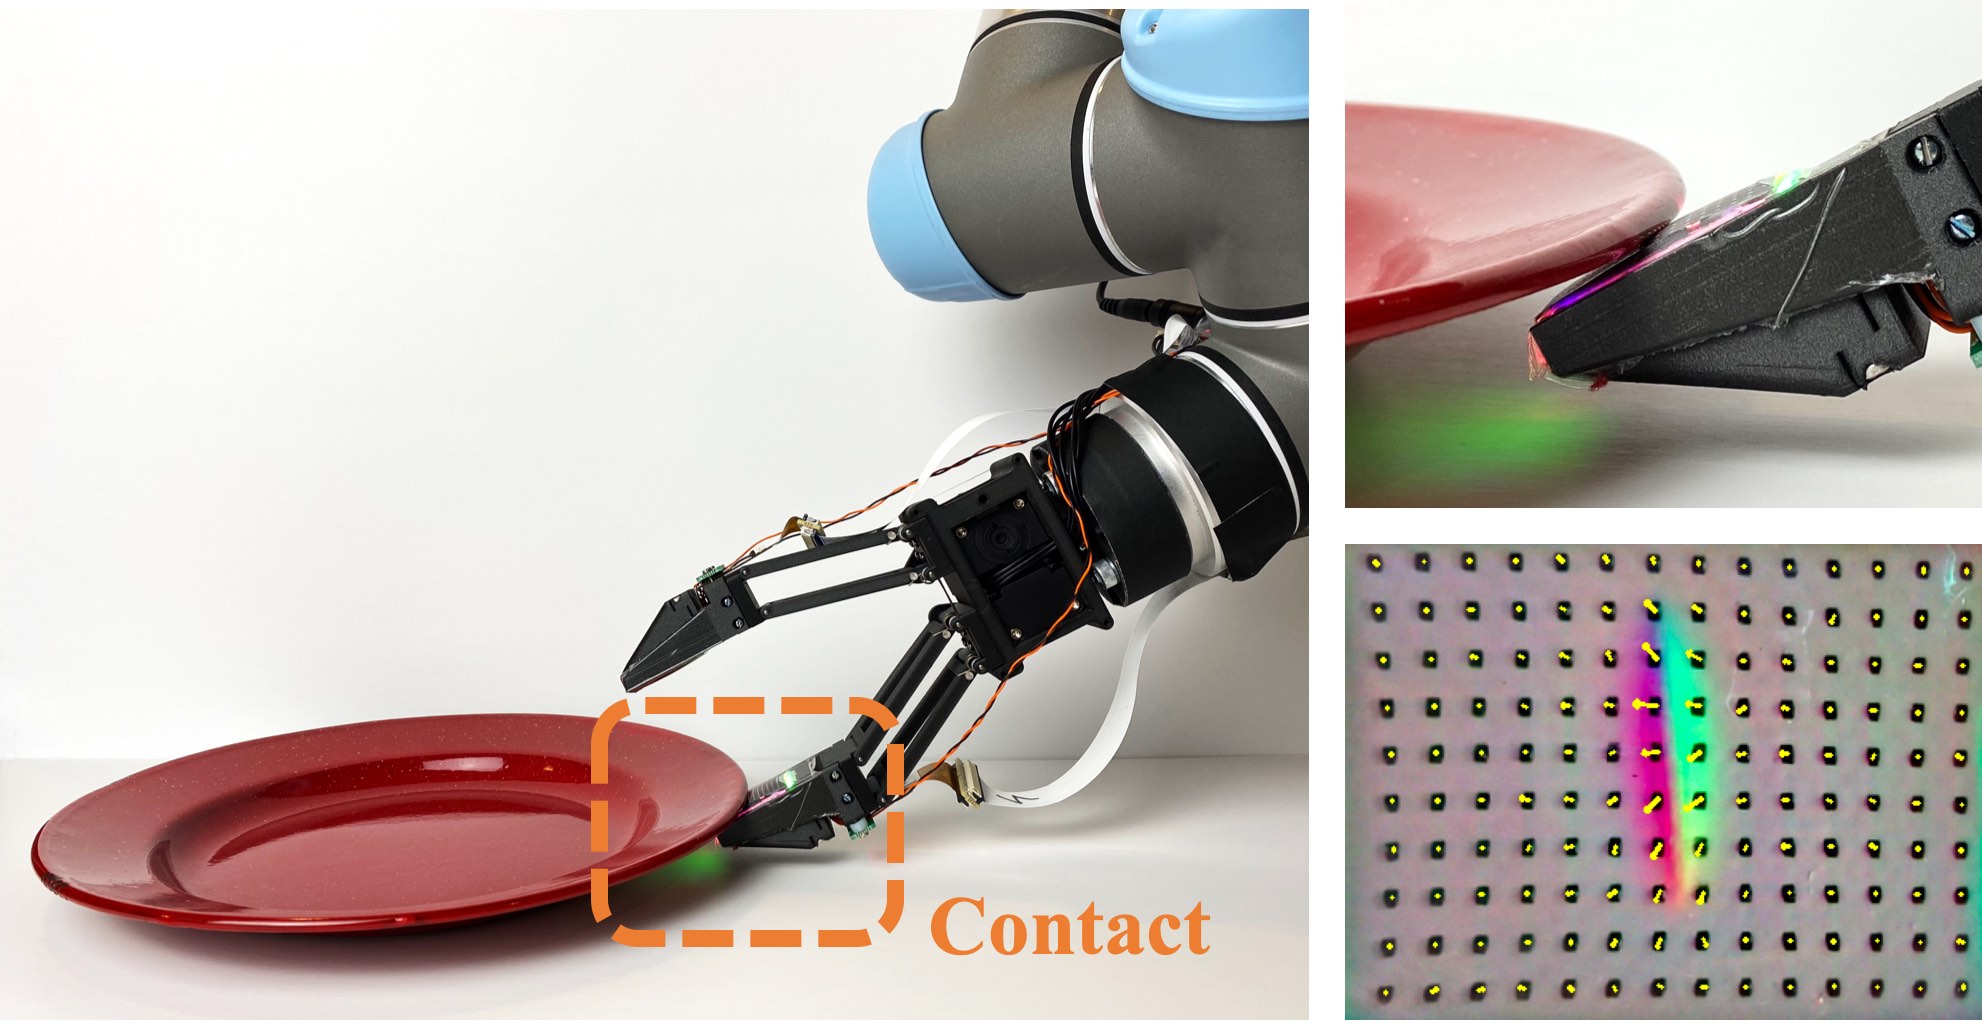
Tactile-Reactive Roller Grasper
Shenli Yuan*, Shaoxiong Wang*, Radhen Patel, Megha Tippur, Connor Yako, Mark R. Cutkosky, Edward H. Adelson†, Kenneth Salisbury†
T-RO, 2025
project page / paper
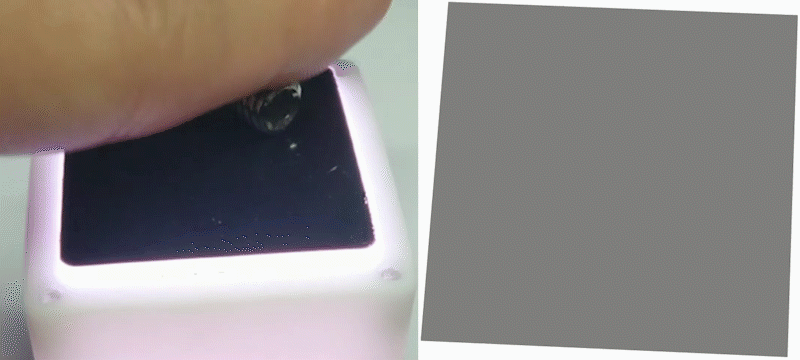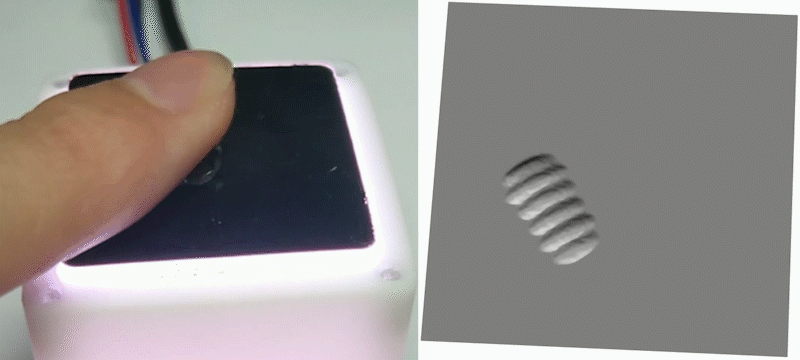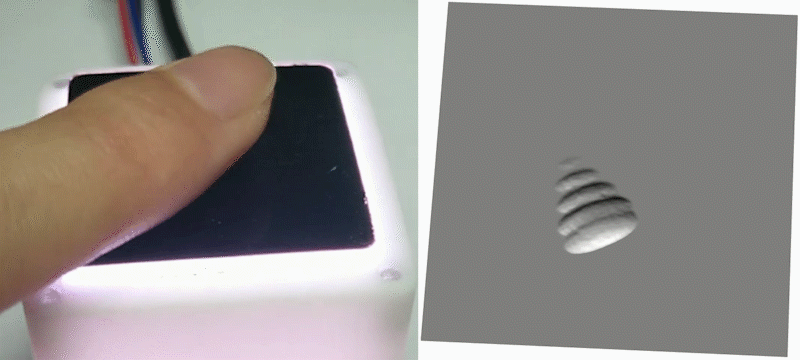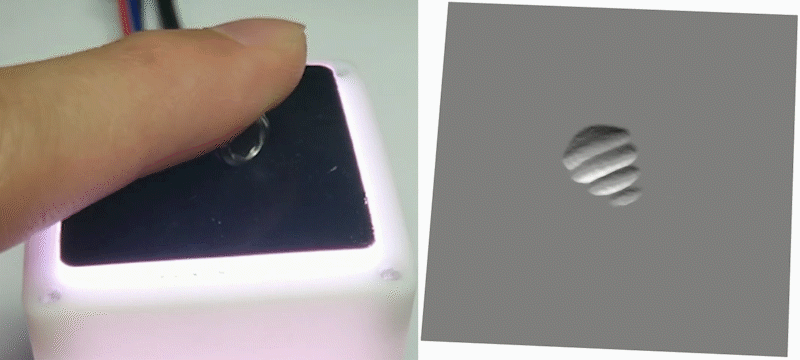
DTact DTact: A Vision-Based Tactile Sensor that Measures High-Resolution 3D Geometry Directly from Darkness
Changyi Lin, Ziqi Lin, Shaoxiong Wang, Huazhe Xu
ICRA, 2023
project page / arXiv
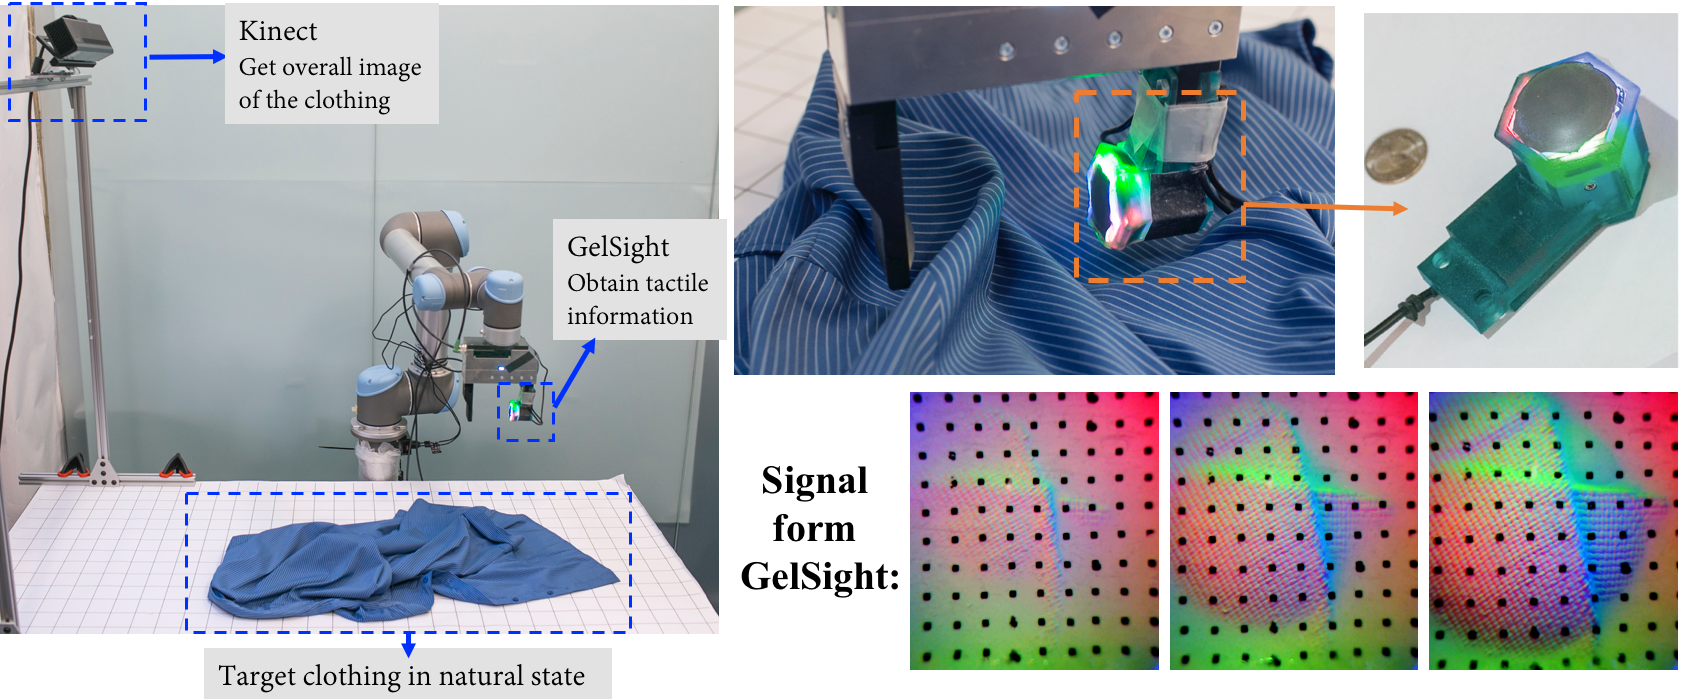
Visuotactile Affordances for Cloth Manipulation with Local Control
Neha Sunil*, Shaoxiong Wang*, Yu She, Edward H. Adelson, Alberto Rodriguez
CoRL, 2022
project page / arXiv
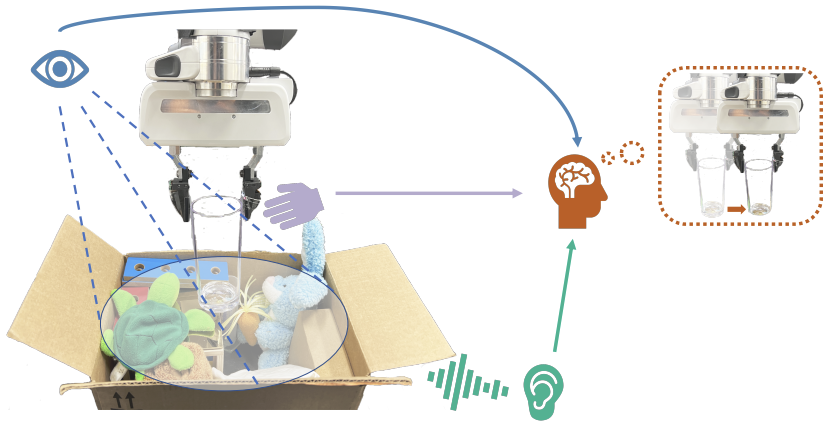
See, Hear, Feel See, Hear, Feel: Smart Sensory Fusion for Robotic Manipulation
Hao Li*, Yizhi Zhang*, Junzhe Zhu, Shaoxiong Wang, Michelle A. Lee, Huazhe Xu, Edward H. Adelson, Li Fei-Fei, Ruohan Gao†, Jiajun Wu†
CoRL, 2022
project page / arXiv
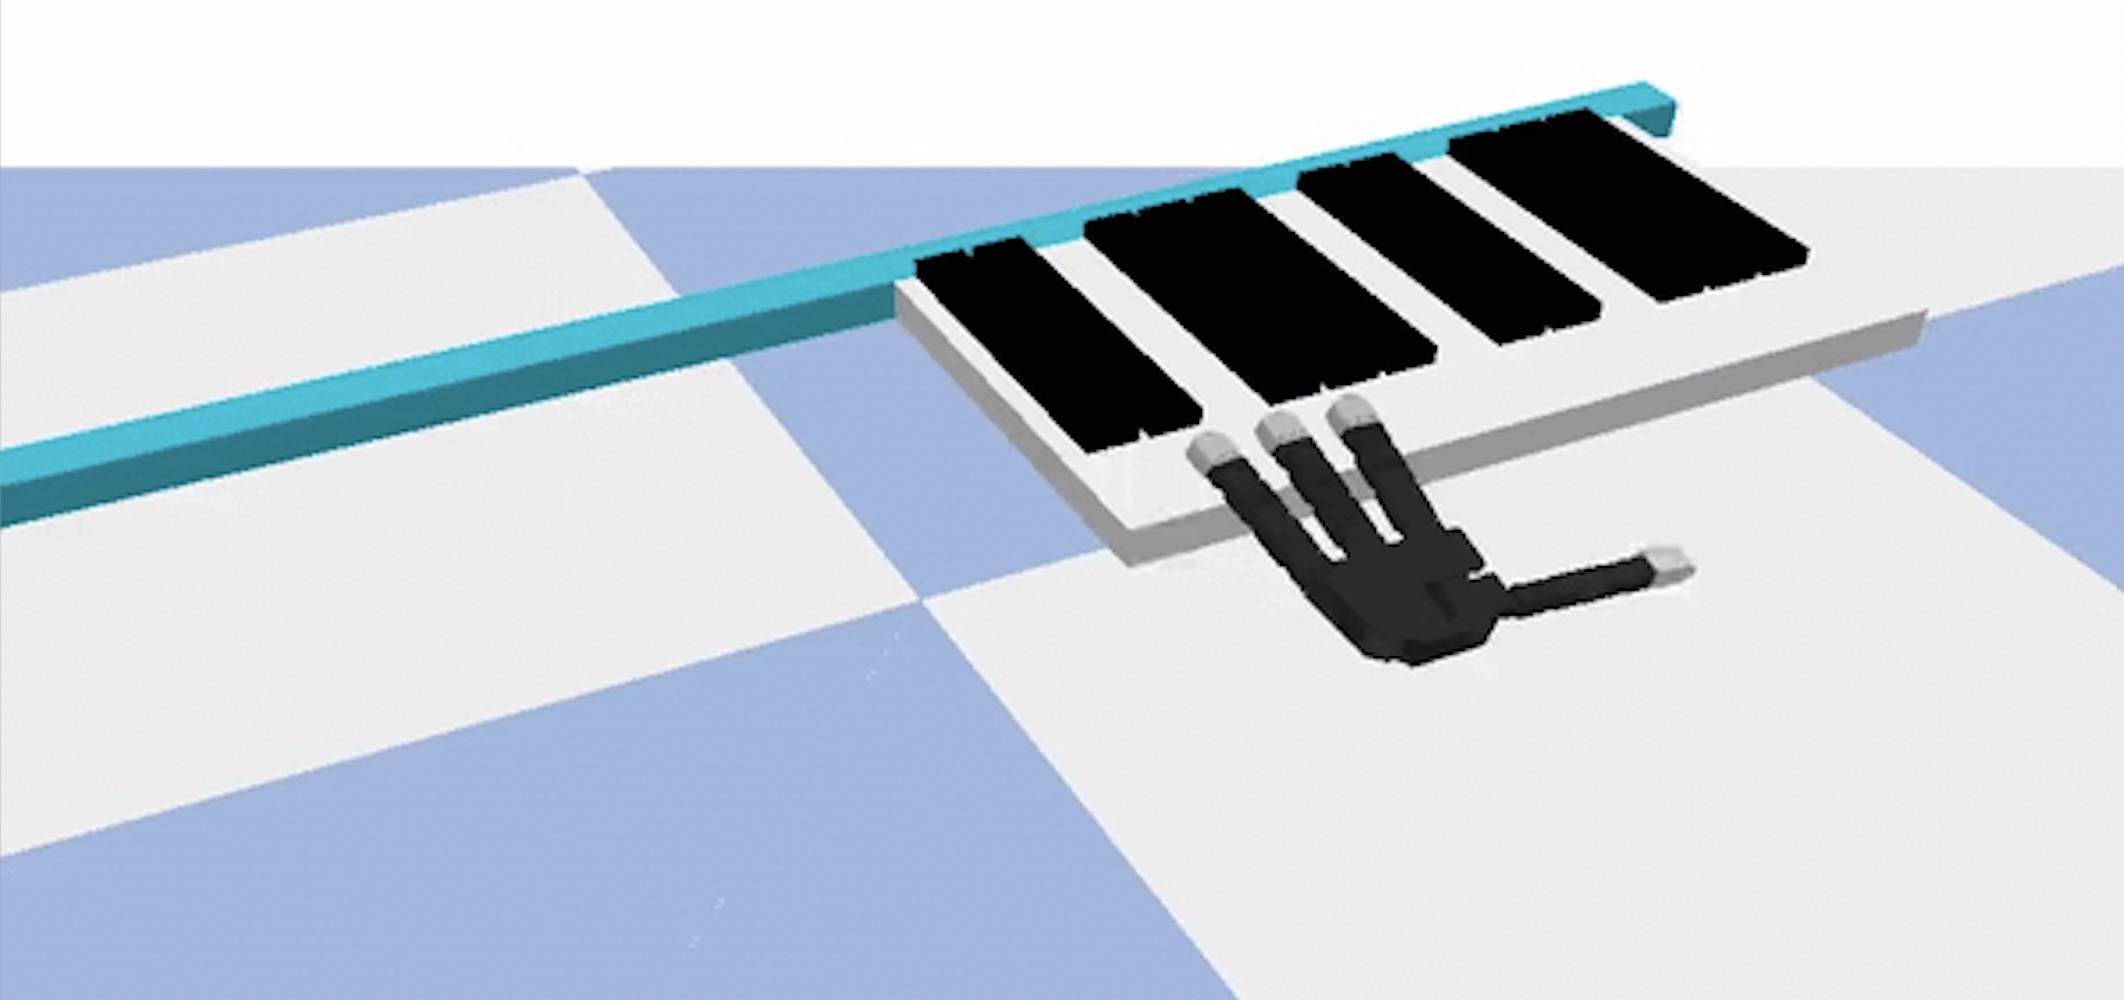
Piano Towards Learning to Play Piano with Dexterous Hands and Touch
Huazhe Xu, Yuping Luo, Shaoxiong Wang, Trevor Darrell, Roberto Calandra
IROS, 2022
arXiv
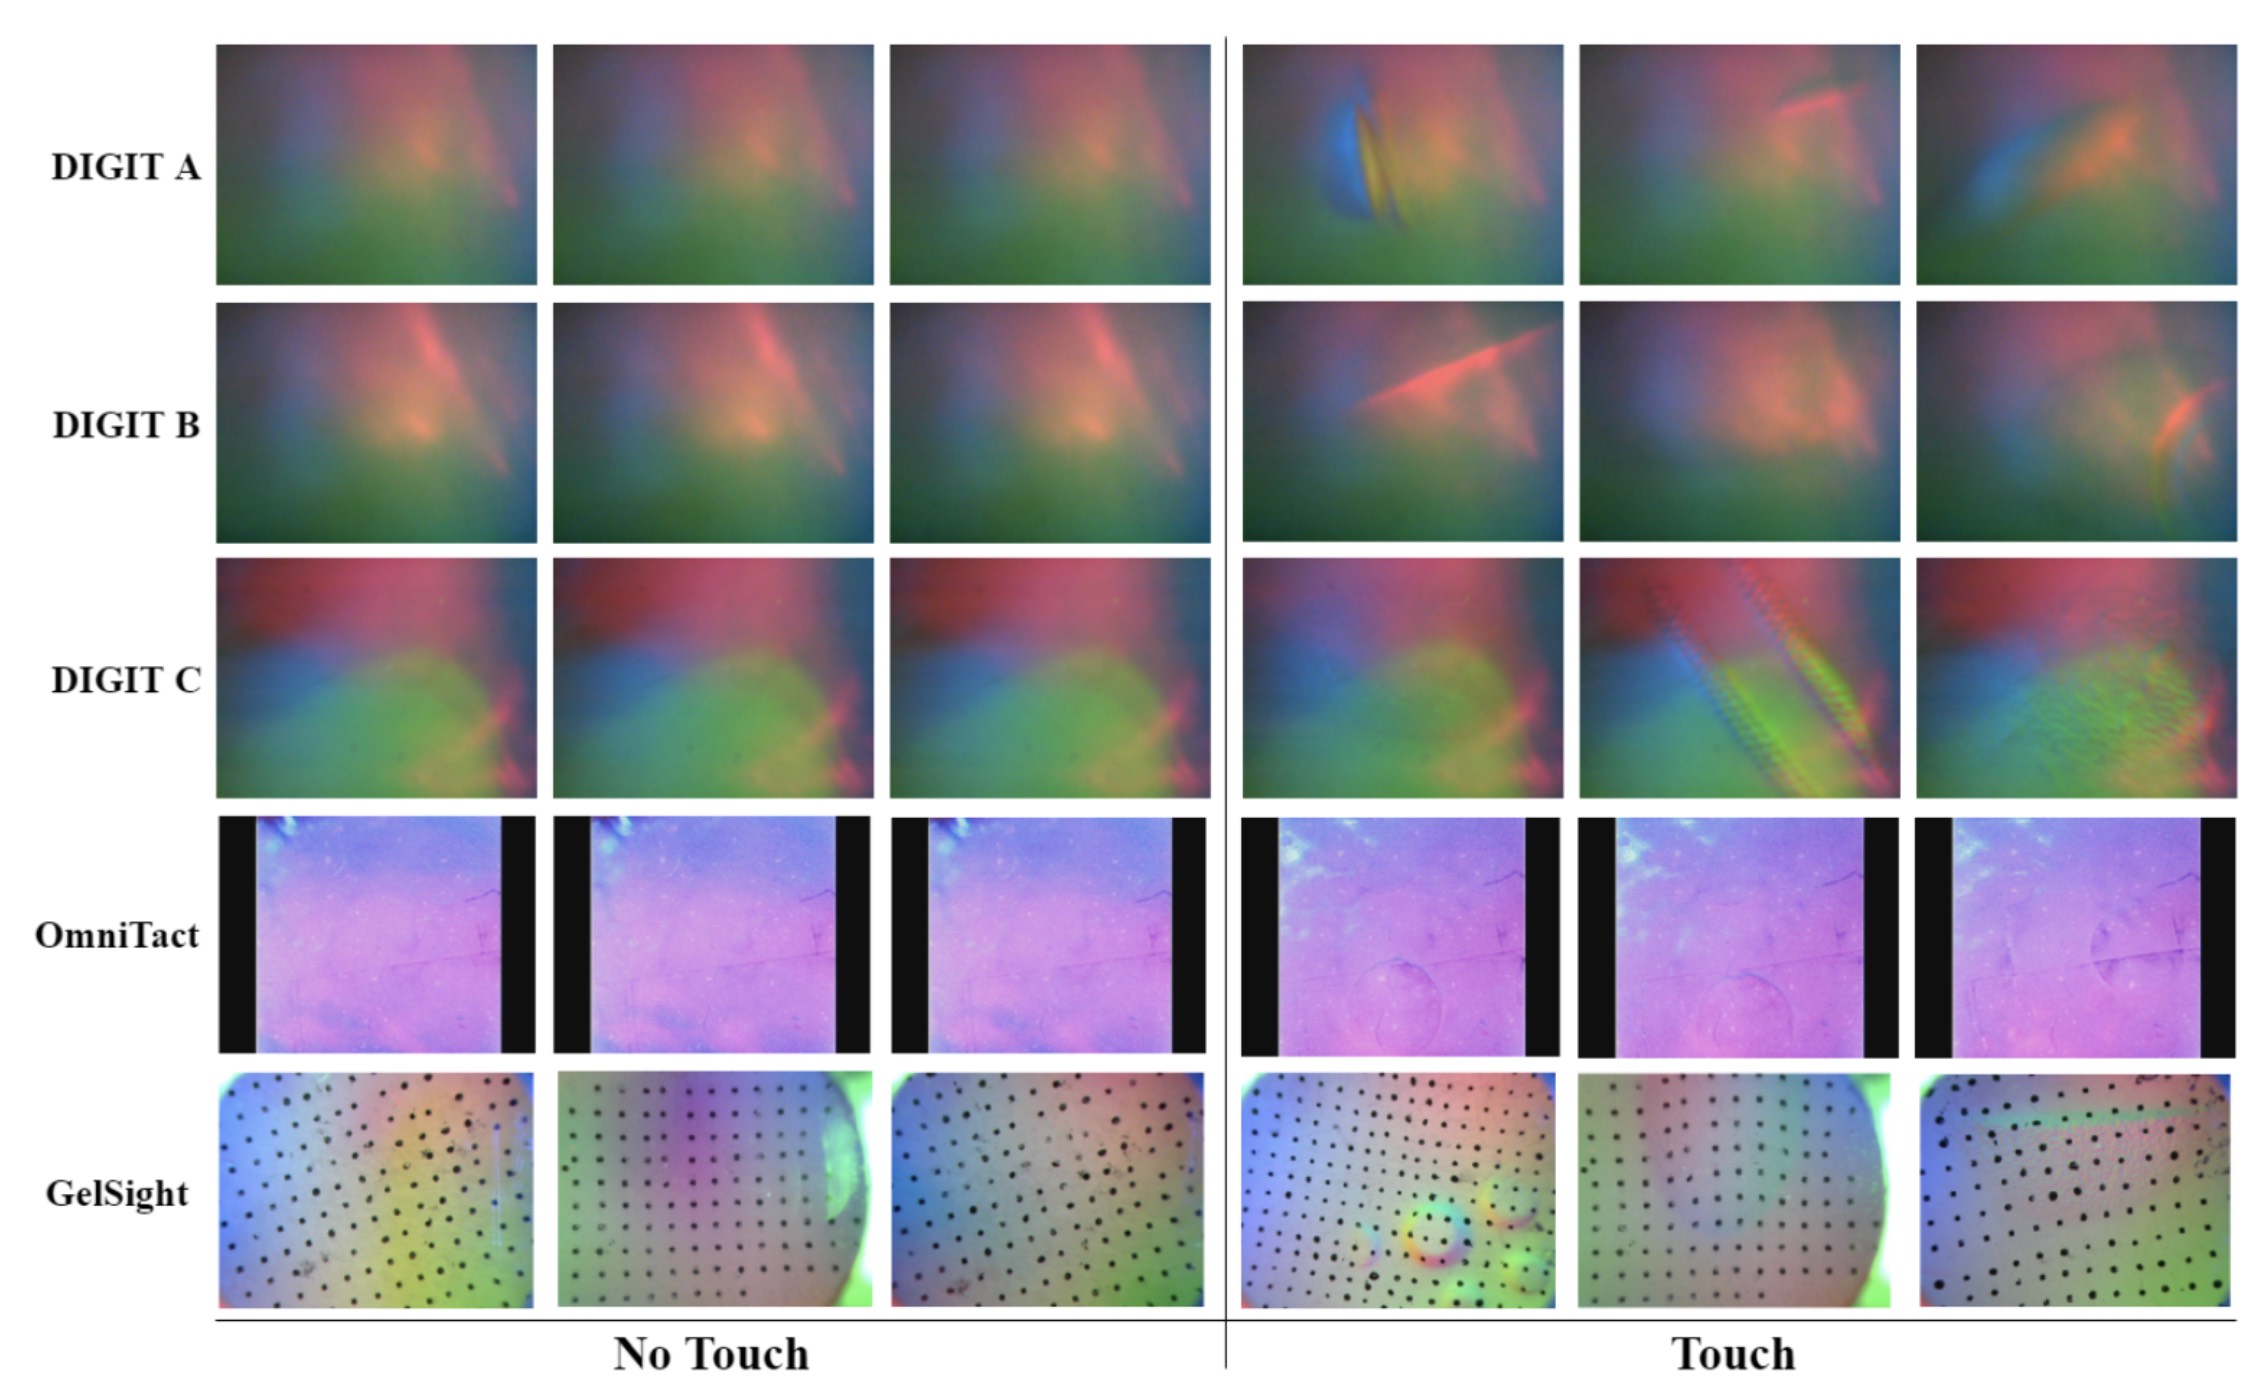
TACTO: A Fast, Flexible, and Open-Source Simulator for High-Resolution Vision-Based Tactile Sensors
Shaoxiong Wang, Michael Lambeta, Po-Wei Chou, Roberto Calandra
RA-L & ICRA, 2022  (NeurIPS 2020 Workshops: Robot Learning; Deep Reinforcement Learning)
code / arXiv
GelSight Wedge GelSight Wedge: Measuring High-Resolution 3D Contact Geometry with a Compact Robot Finger
Shaoxiong Wang, Yu She, Branden Romero, Edward H. Adelson
ICRA, 2021
project page / arXiv
PyTouch PyTouch: A Machine Learning Library for Touch Processing
Michael Lambeta, Huazhe Xu, Jingwei Xu, Po-Wei Chou, Shaoxiong Wang, Trevor Darrell, Roberto Calandra
ICRA, 2021
code / arXiv
SwingBot: Learning Physical Features from In-Hand Tactile Exploration for Dynamic Swing-up Manipulation
Chen Wang*, Shaoxiong Wang*, Branden Romero, Filipe Veiga, Edward H. Adelson
IROS, 2020  (Best Paper Award)
project page / paper / MIT CSAIL news
Cable Manipulation with a Tactile-Reactive Gripper
Yu She*, Shaoxiong Wang*, Siyuan Dong*, Neha Sunil, Alberto Rodriguez, Edward H. Adelson
RSS, 2020  (Best Paper Award Finalist)
IJRR, 2021
project page / arXiv / MIT News
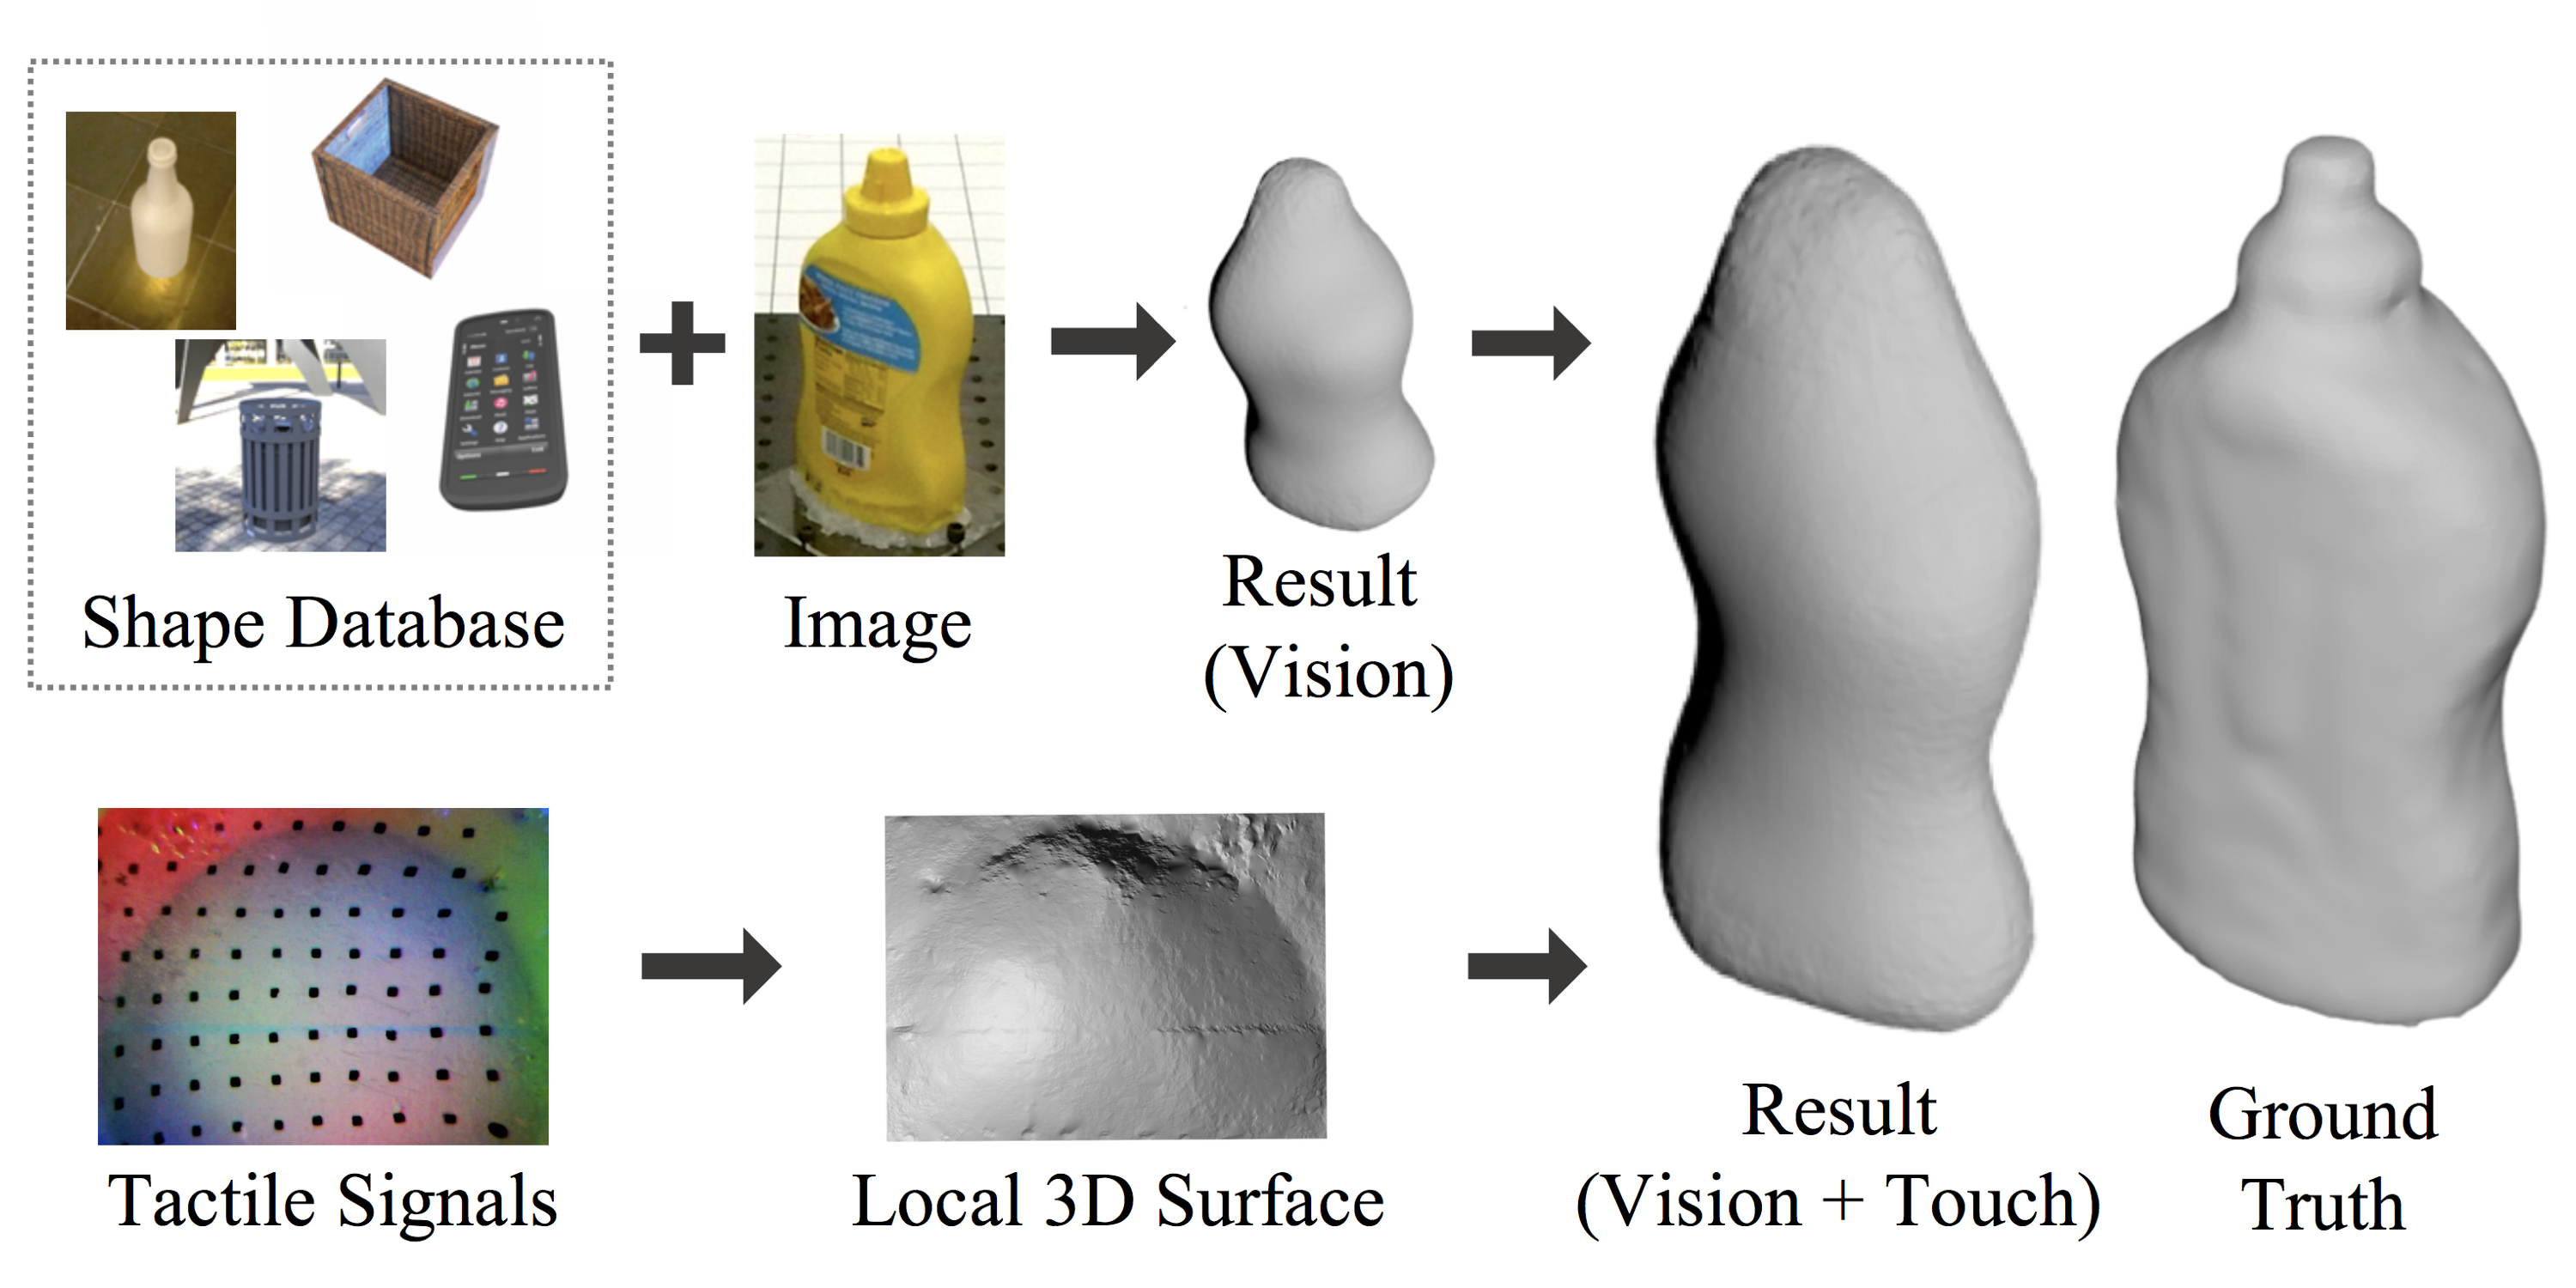
3D Shape Perception 3D Shape Perception from Monocular Vision, Touch, and Shape Priors
Shaoxiong Wang*, Jiajun Wu*, Xingyuan Sun, Wenzhen Yuan, William T. Freeman, Joshua B. Tenenbaum, Edward H. Adelson
IROS, 2018
project page / arXiv
Active Clothing Perception Active Clothing Material Perception using Tactile Sensing and Machine Learning
Wenzhen Yuan, Yuchen Mo, Shaoxiong Wang, Edward H. Adelson
ICRA, 2018
project page / arXiv / data
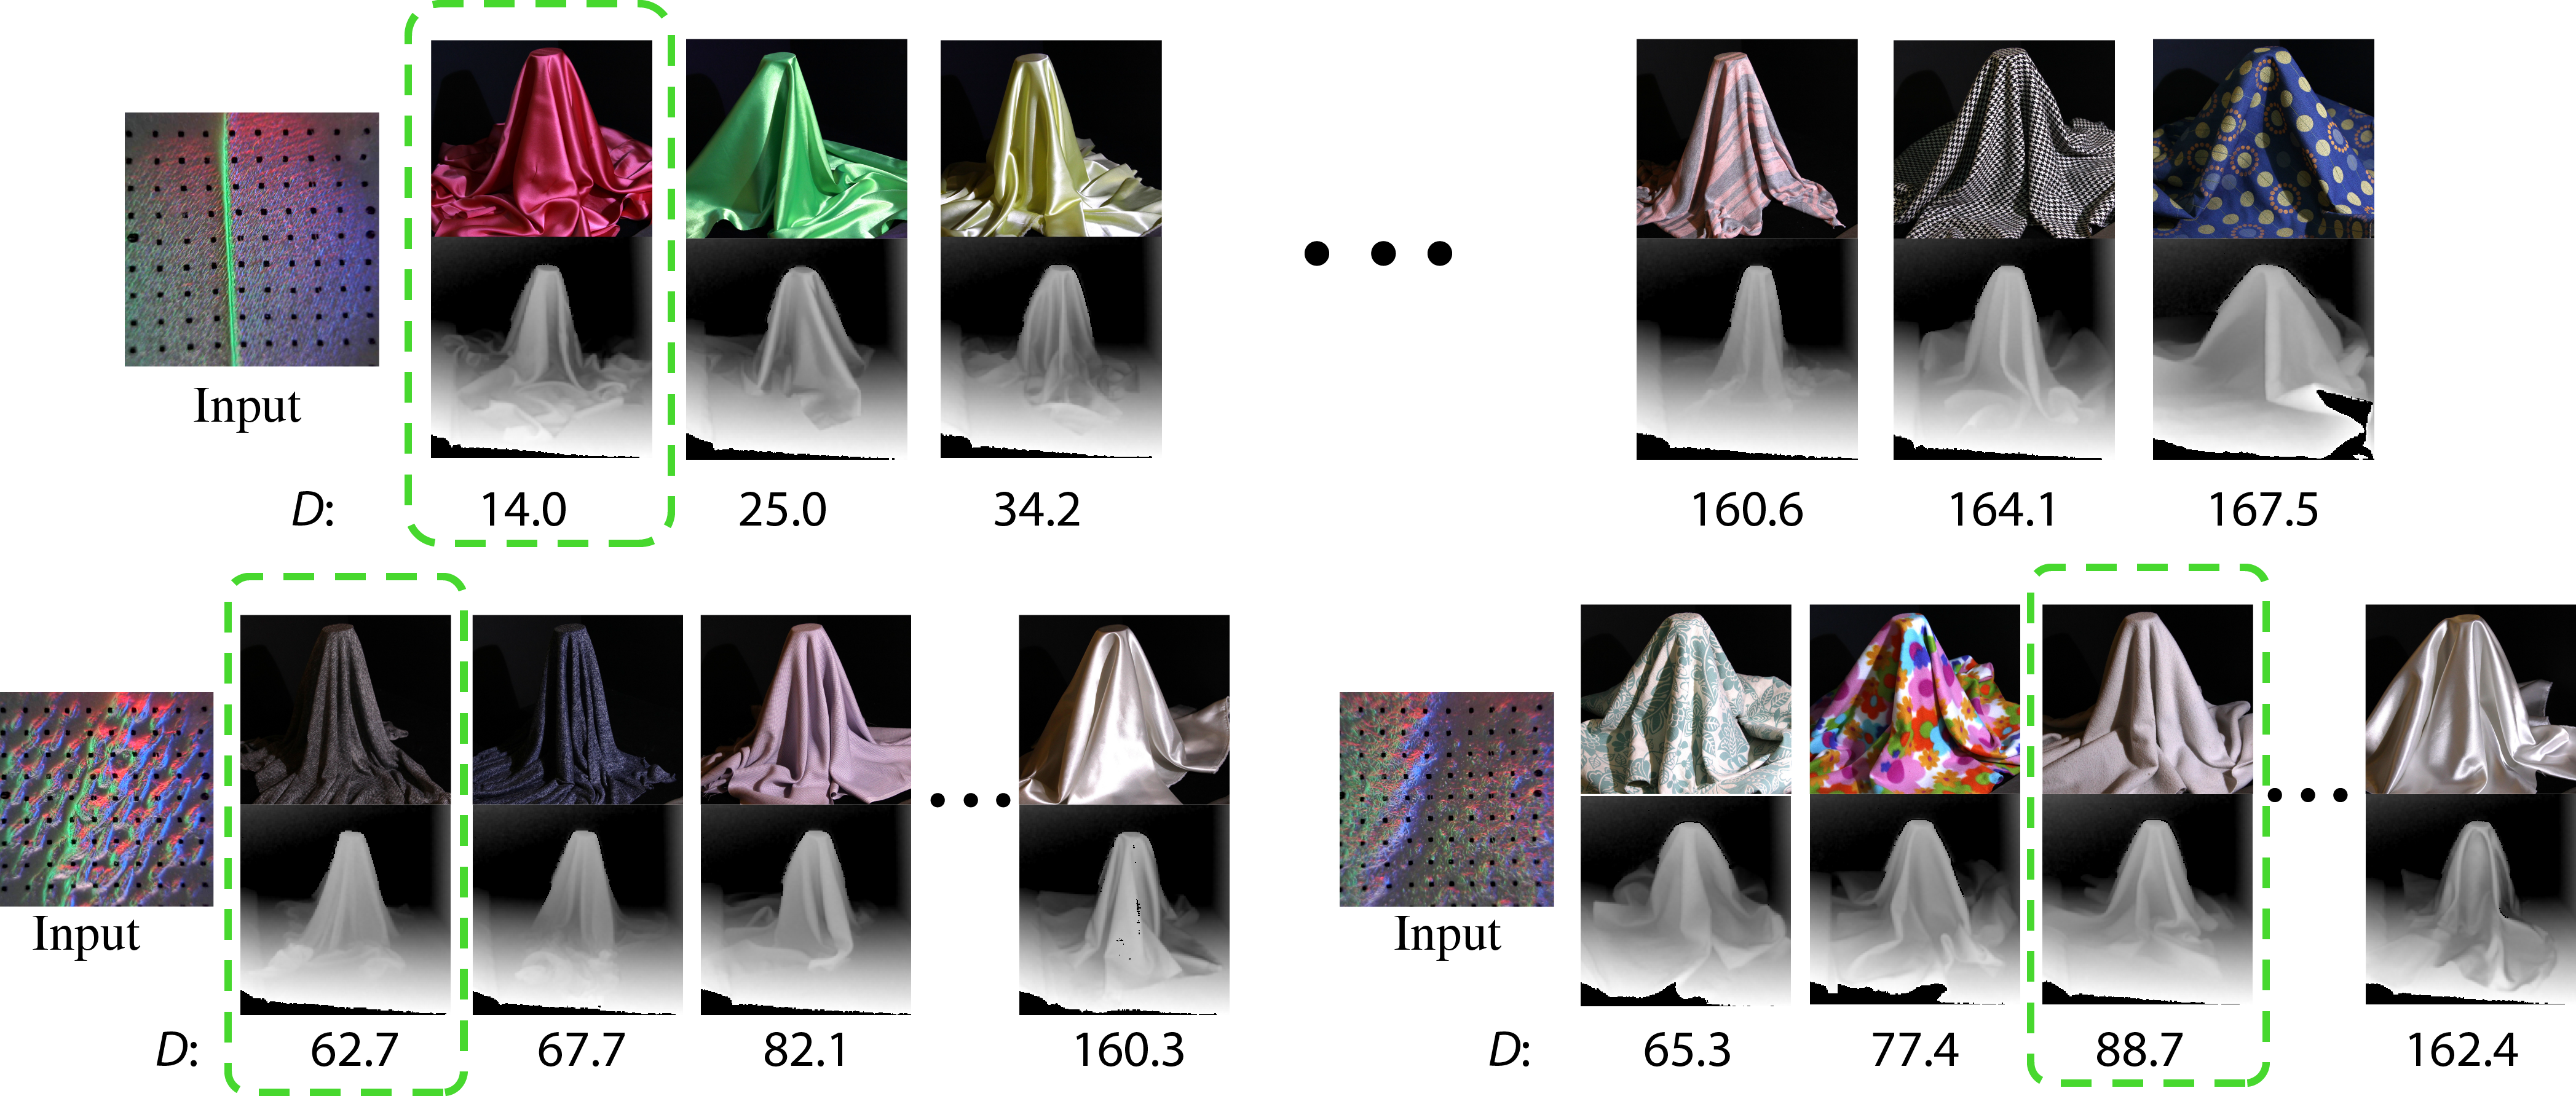
Connecting Look and Feel Connecting Look and Feel: Associating the Visual and Tactile Properties of Physical Materials
Wenzhen Yuan*, Shaoxiong Wang*, Siyuan Dong, Edward H. Adelson
CVPR, 2017  (Oral)
project page / paper / data
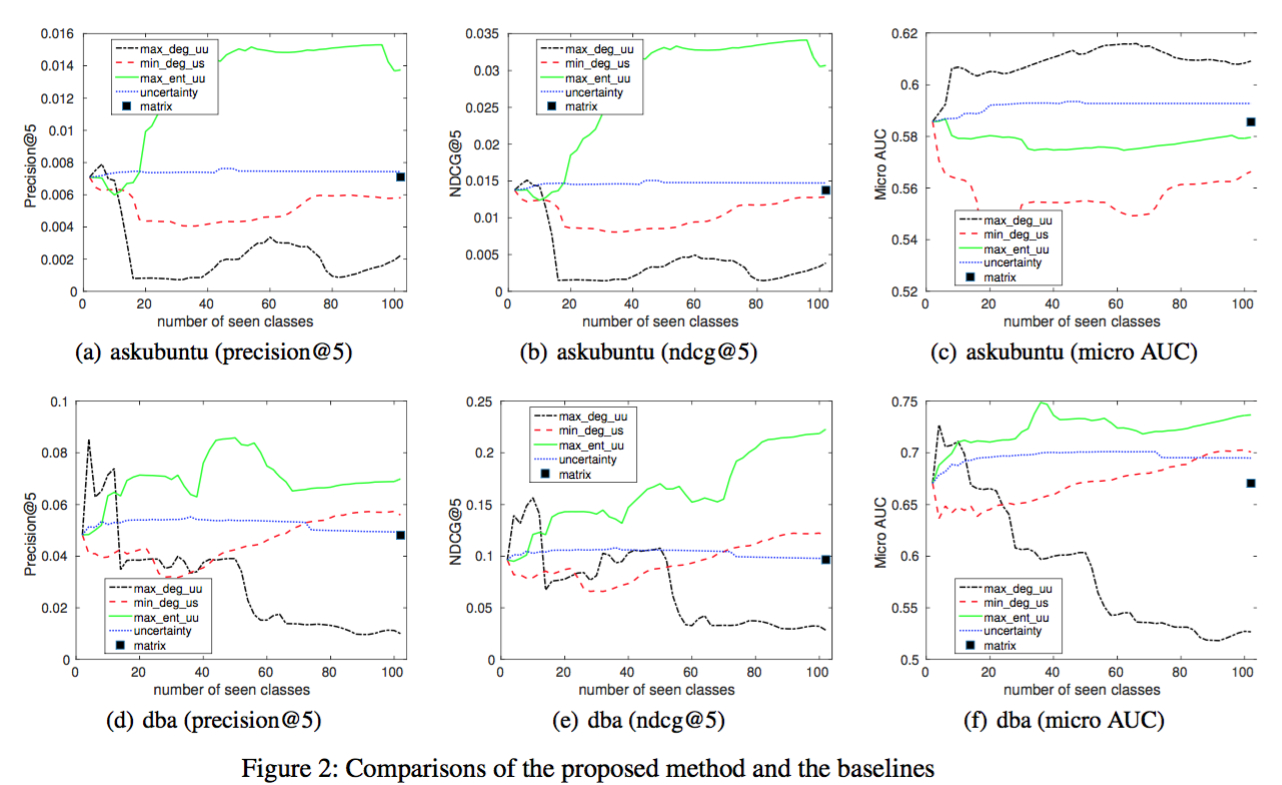
Active Zero-Shot Learning Active Zero-Shot Learning
Sihong Xie, Shaoxiong Wang, Philip S. Yu
CIKM, 2016
paper / data

Side Projects

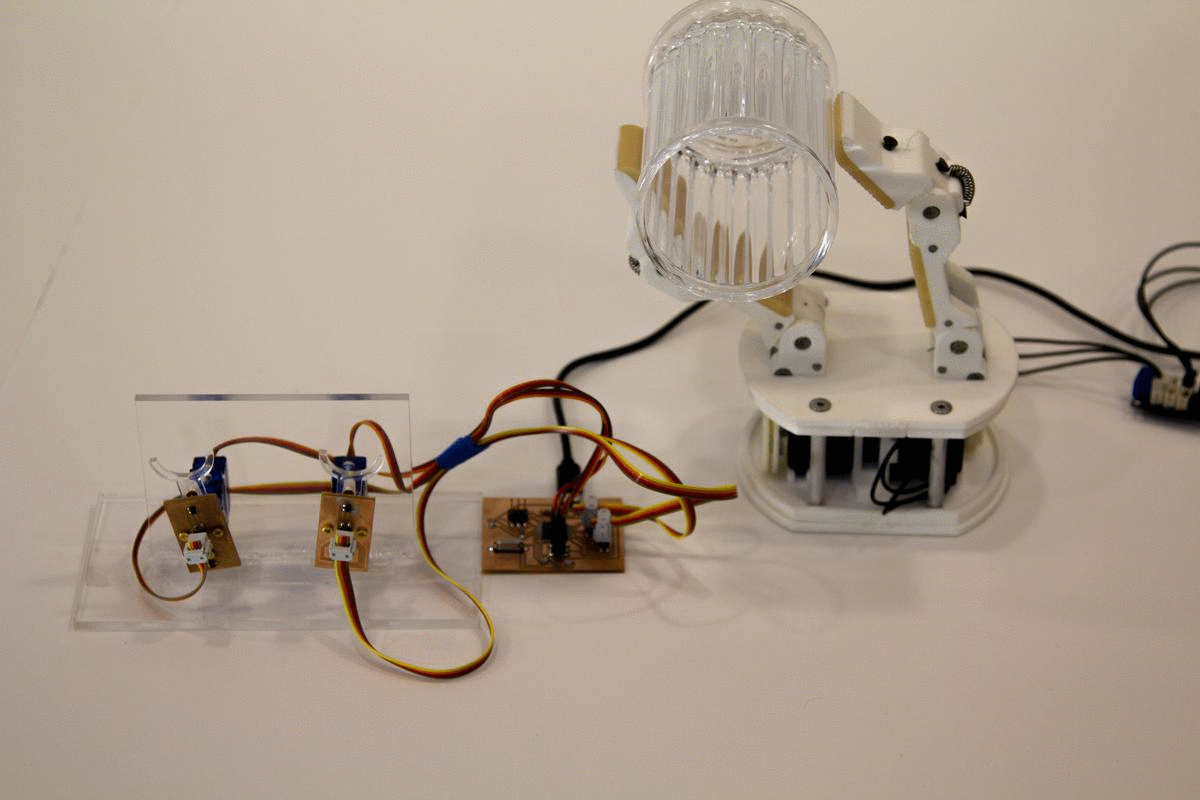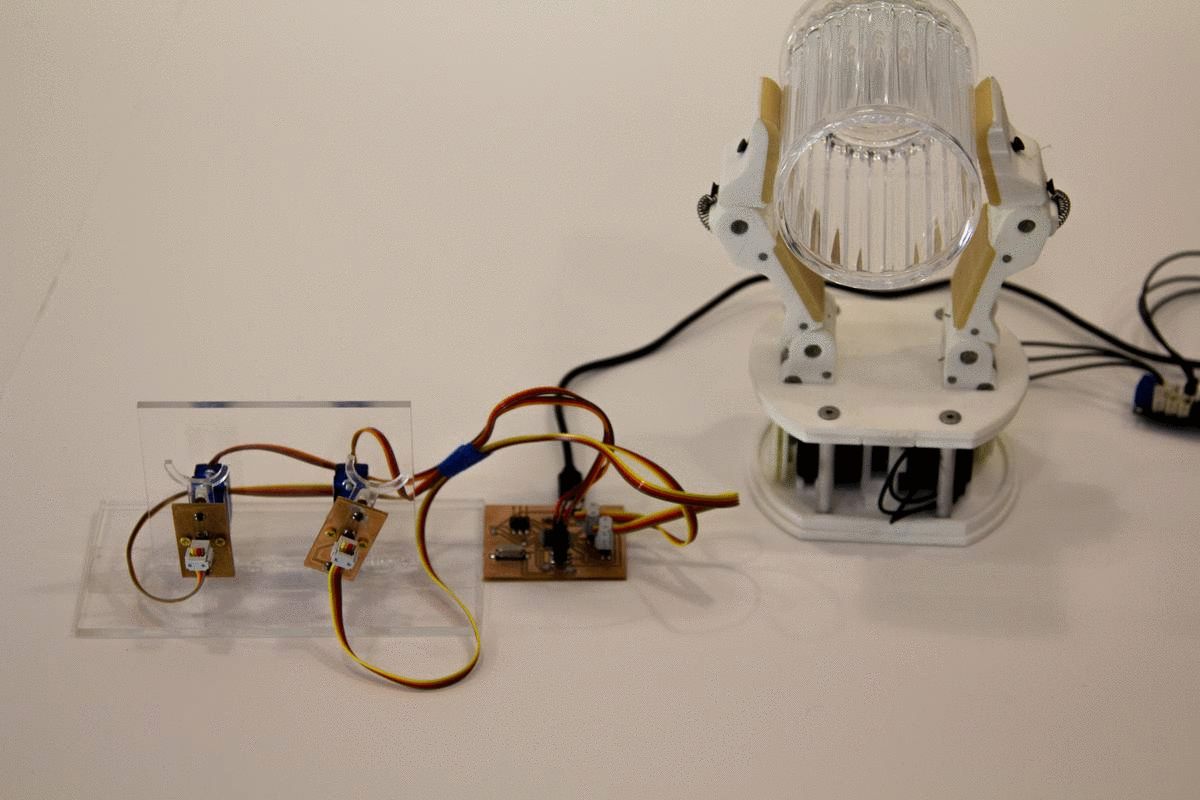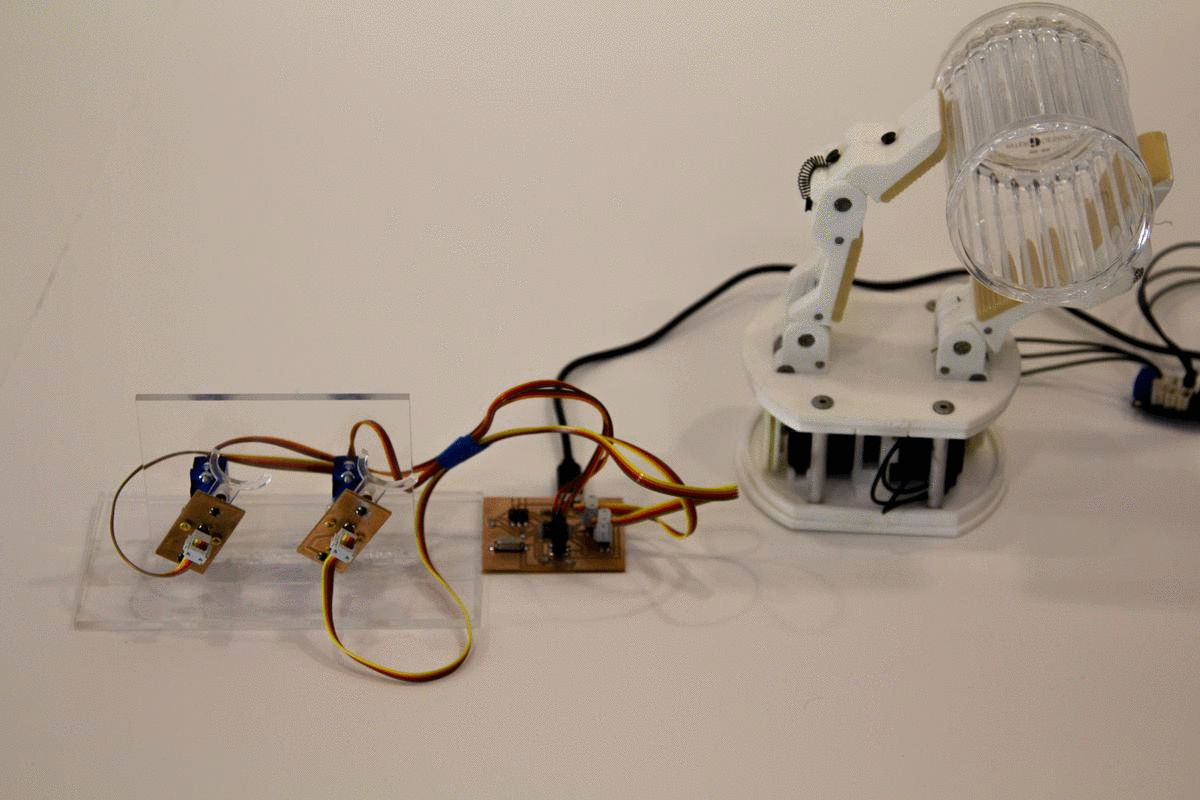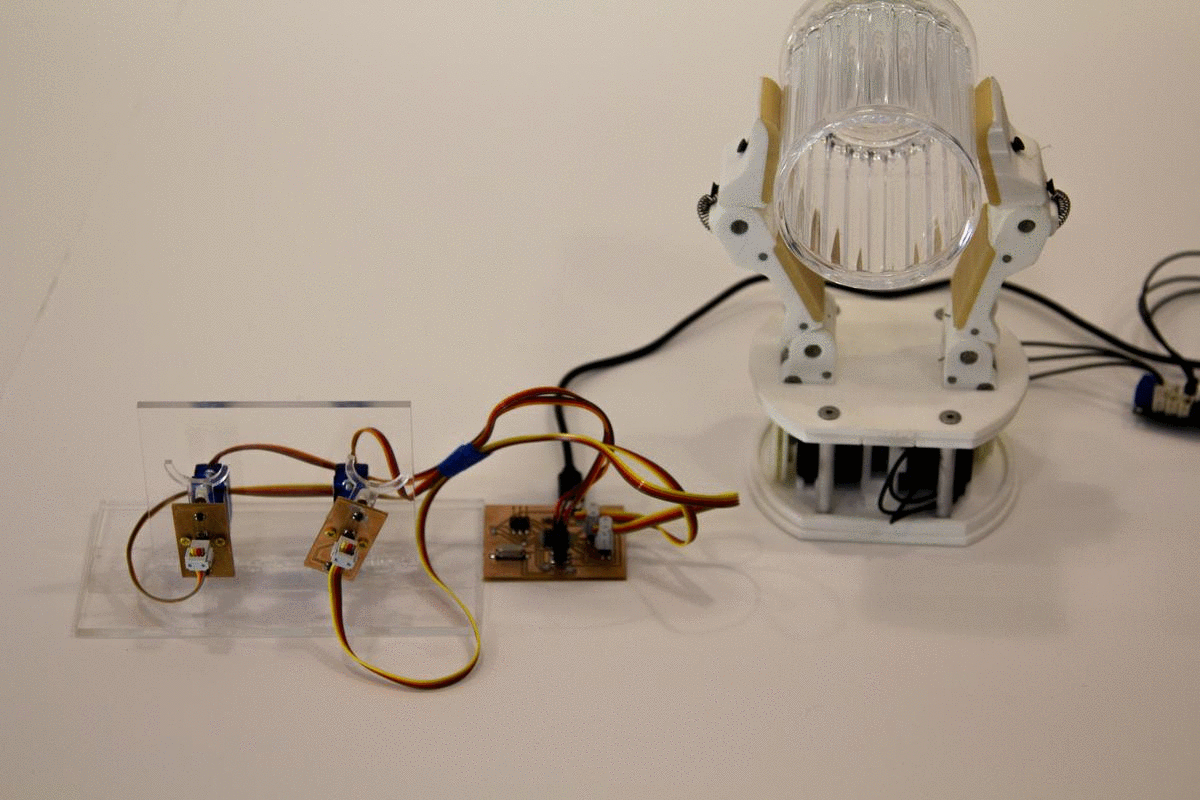
How To Make (Almost) Anything MIT 6.943[J] How To Make (Almost) Anything
video / website

Teleoperation with force feedback: an ATmega16U4 micro-controller with USB support via the LUFA library, Hall-effect sensors & magnets for force sensing, and a 3D-printed cable-driven robot hand (Yale OpenHand).

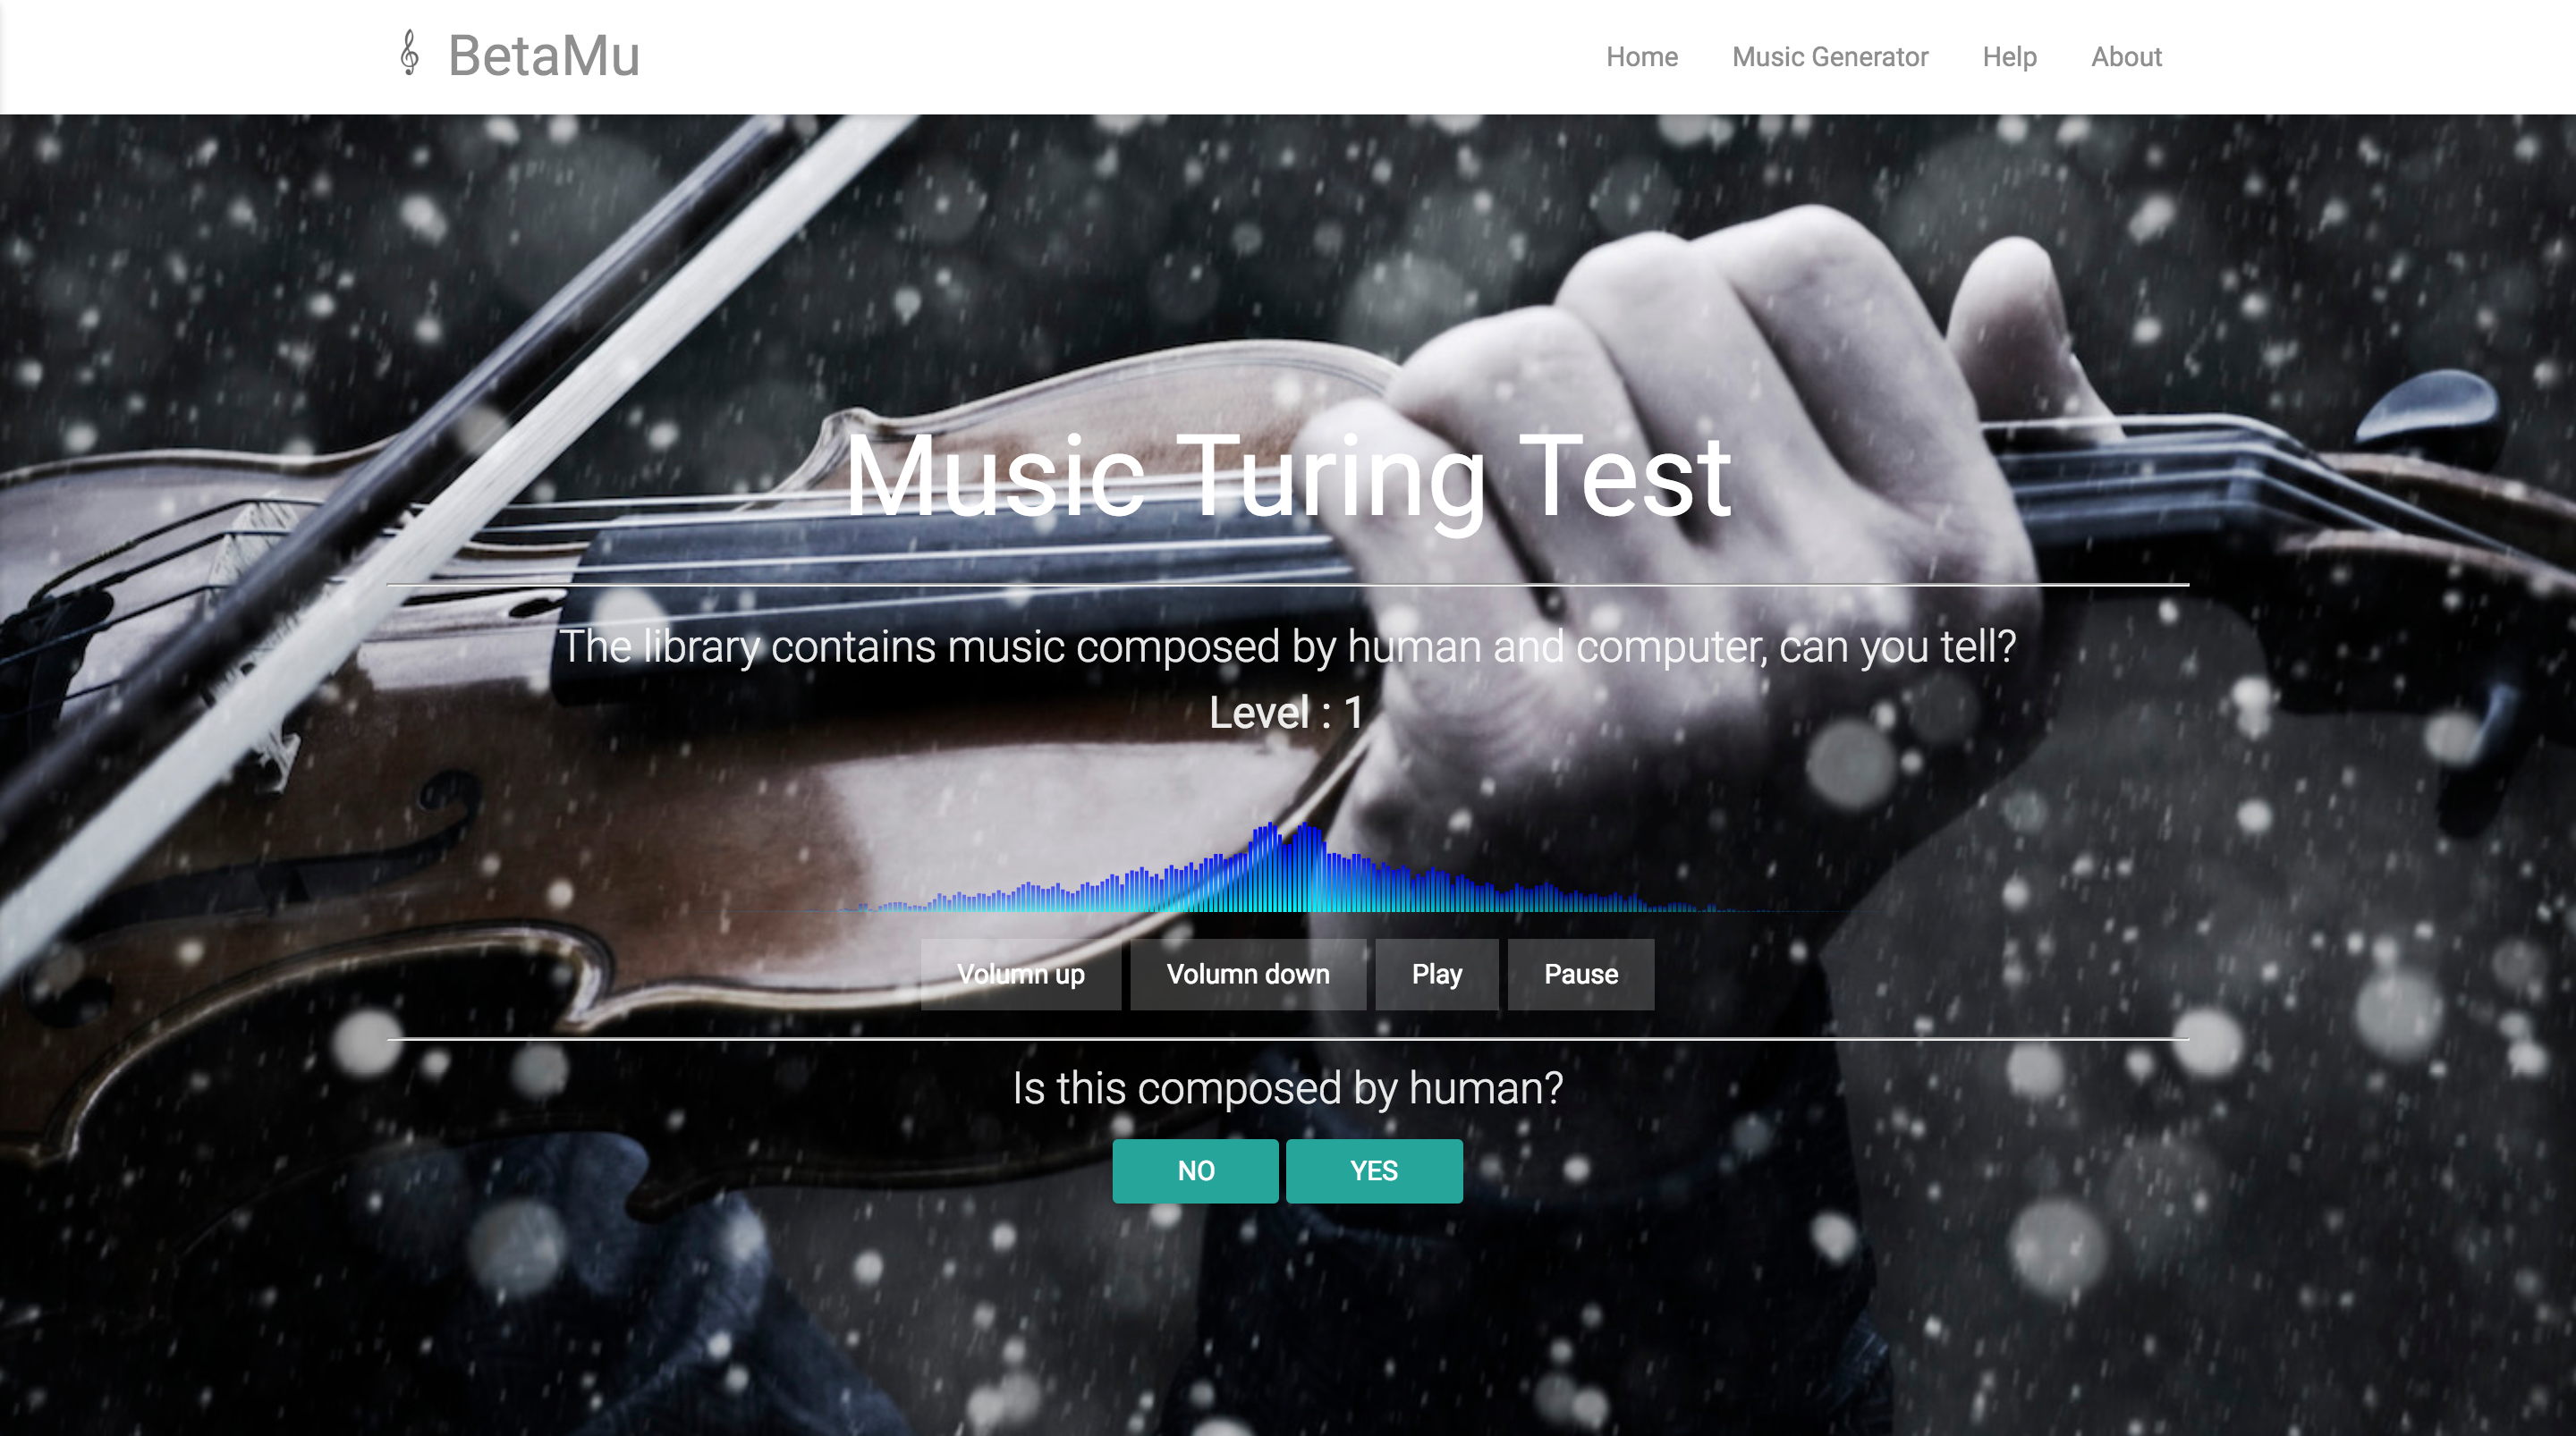
Music Generation Music Generation with Long Short-Term Memory
1st Place in Microsoft Campus Elite Program (news)
Grand Prize in 35th Tsinghua Challenge Cup, top 6 among 381 teams (news)

A comprehensive music generation system based on Long Short-Term Memory (LSTM) networks. It generates music automatically driven by data and is embedded with rich music knowledge.
Website template from Jon Barron.