Shaoxiong (Shawn) Wang

I'm a Member of Technical Staff at Tacta. I received my Ph.D. degree from the Computer Science and Artificial Intelligence Laboratory (CSAIL), MIT. I was advised by Edward H. Adelson, and also worked closely with Alberto Rodriguez. During my Ph.D., I worked with Roberto Calandra at Facebook AI Research. I obtained my bachelor's degree from the Department of Computer Science and Technology, Tsinghua University, where I worked with Jie Tang in the Knowledge Engineering Group.

wsxiong13 [at] gmail (dot) com
Scholar  /  Github  /  X  /  LinkedIn

profile photo

Publications

During my Ph.D., I studied tactile perception & manipulation, computer vision, and machine learning. Some papers are highlighted. * and † indicate equal contribution.

Tactile-Reactive Roller Grasper
Shenli Yuan*, Shaoxiong Wang*, Radhen Patel, Megha Tippur, Connor Yako, Mark R. Cutkosky, Edward H. Adelson†, Kenneth Salisbury†
T-RO, 2025
project page / paper
In-Hand Singulation, Scooping, and Cable Untangling with a 5-DOF Tactile-Reactive Gripper
Yuhao Zhou*, Pokuang Zhou*, Shaoxiong Wang, Yu She
IROS, 2024
Advanced Robotics Research, 2025  (Front Cover Feature)
project page / arXiv / paper / video
DTact: A Vision-Based Tactile Sensor that Measures High-Resolution 3D Geometry Directly from Darkness
Changyi Lin, Ziqi Lin, Shaoxiong Wang, Huazhe Xu
ICRA, 2023
project page / arXiv
Visuotactile Affordances for Cloth Manipulation with Local Control
Neha Sunil*, Shaoxiong Wang*, Yu She, Edward H. Adelson, Alberto Rodriguez
CoRL, 2022
project page / arXiv
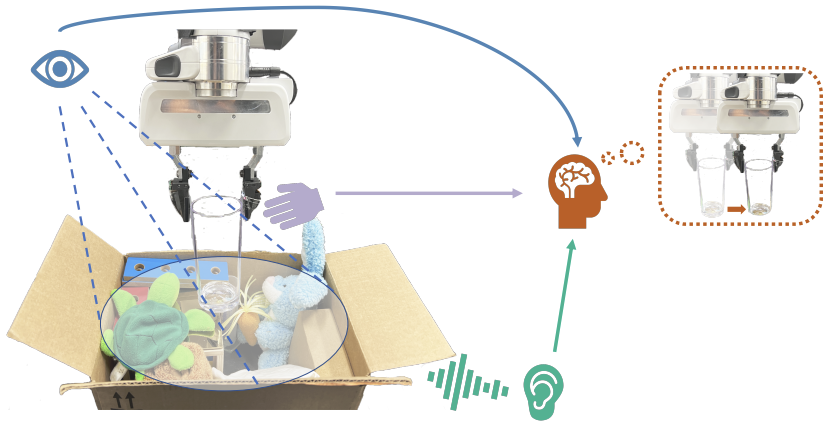
See, Hear, Feel See, Hear, Feel: Smart Sensory Fusion for Robotic Manipulation
Hao Li*, Yizhi Zhang*, Junzhe Zhu, Shaoxiong Wang, Michelle A. Lee, Huazhe Xu, Edward H. Adelson, Li Fei-Fei, Ruohan Gao†, Jiajun Wu†
CoRL, 2022
project page / arXiv
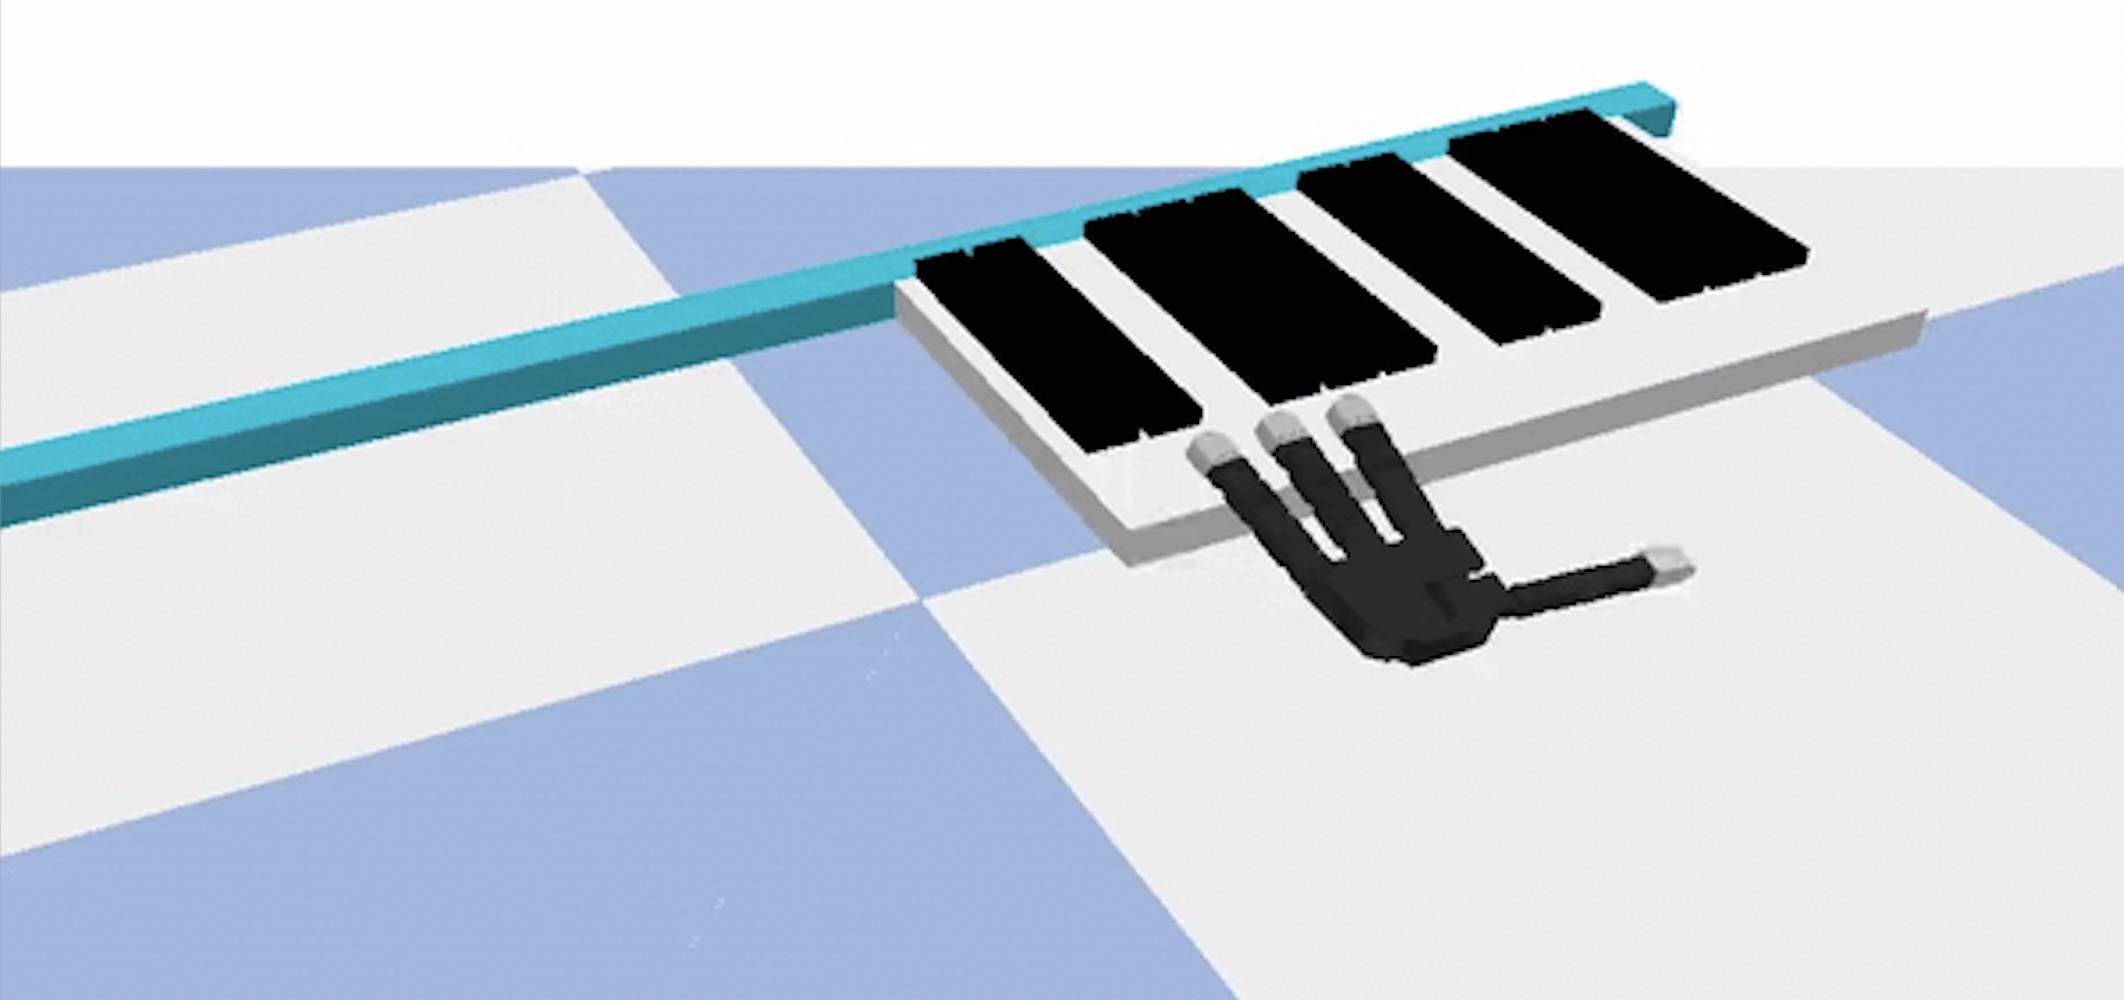
Piano Towards Learning to Play Piano with Dexterous Hands and Touch
Huazhe Xu, Yuping Luo, Shaoxiong Wang, Trevor Darrell, Roberto Calandra
IROS, 2022
arXiv
TACTO: A Fast, Flexible, and Open-Source Simulator for High-Resolution Vision-Based Tactile Sensors
Shaoxiong Wang, Michael Lambeta, Po-Wei Chou, Roberto Calandra
RA-L & ICRA, 2022  (NeurIPS 2020 Workshops: Robot Learning; Deep Reinforcement Learning)
code / arXiv
GelSight Wedge GelSight Wedge: Measuring High-Resolution 3D Contact Geometry with a Compact Robot Finger
Shaoxiong Wang, Yu She, Branden Romero, Edward H. Adelson
ICRA, 2021
project page / arXiv
PyTouch PyTouch: A Machine Learning Library for Touch Processing
Michael Lambeta, Huazhe Xu, Jingwei Xu, Po-Wei Chou, Shaoxiong Wang, Trevor Darrell, Roberto Calandra
ICRA, 2021
code / arXiv
SwingBot: Learning Physical Features from In-Hand Tactile Exploration for Dynamic Swing-up Manipulation
Chen Wang*, Shaoxiong Wang*, Branden Romero, Filipe Veiga, Edward H. Adelson
IROS, 2020  (Best Paper Award)
project page / paper / MIT CSAIL news
Cable Manipulation with a Tactile-Reactive Gripper
Yu She*, Shaoxiong Wang*, Siyuan Dong*, Neha Sunil, Alberto Rodriguez, Edward H. Adelson
RSS, 2020  (Best Paper Award Finalist)
IJRR, 2021
project page / arXiv / MIT News
3D Shape Perception 3D Shape Perception from Monocular Vision, Touch, and Shape Priors
Shaoxiong Wang*, Jiajun Wu*, Xingyuan Sun, Wenzhen Yuan, William T. Freeman, Joshua B. Tenenbaum, Edward H. Adelson
IROS, 2018
project page / arXiv
Active Clothing Perception Active Clothing Material Perception using Tactile Sensing and Machine Learning
Wenzhen Yuan, Yuchen Mo, Shaoxiong Wang, Edward H. Adelson
ICRA, 2018
project page / arXiv / data
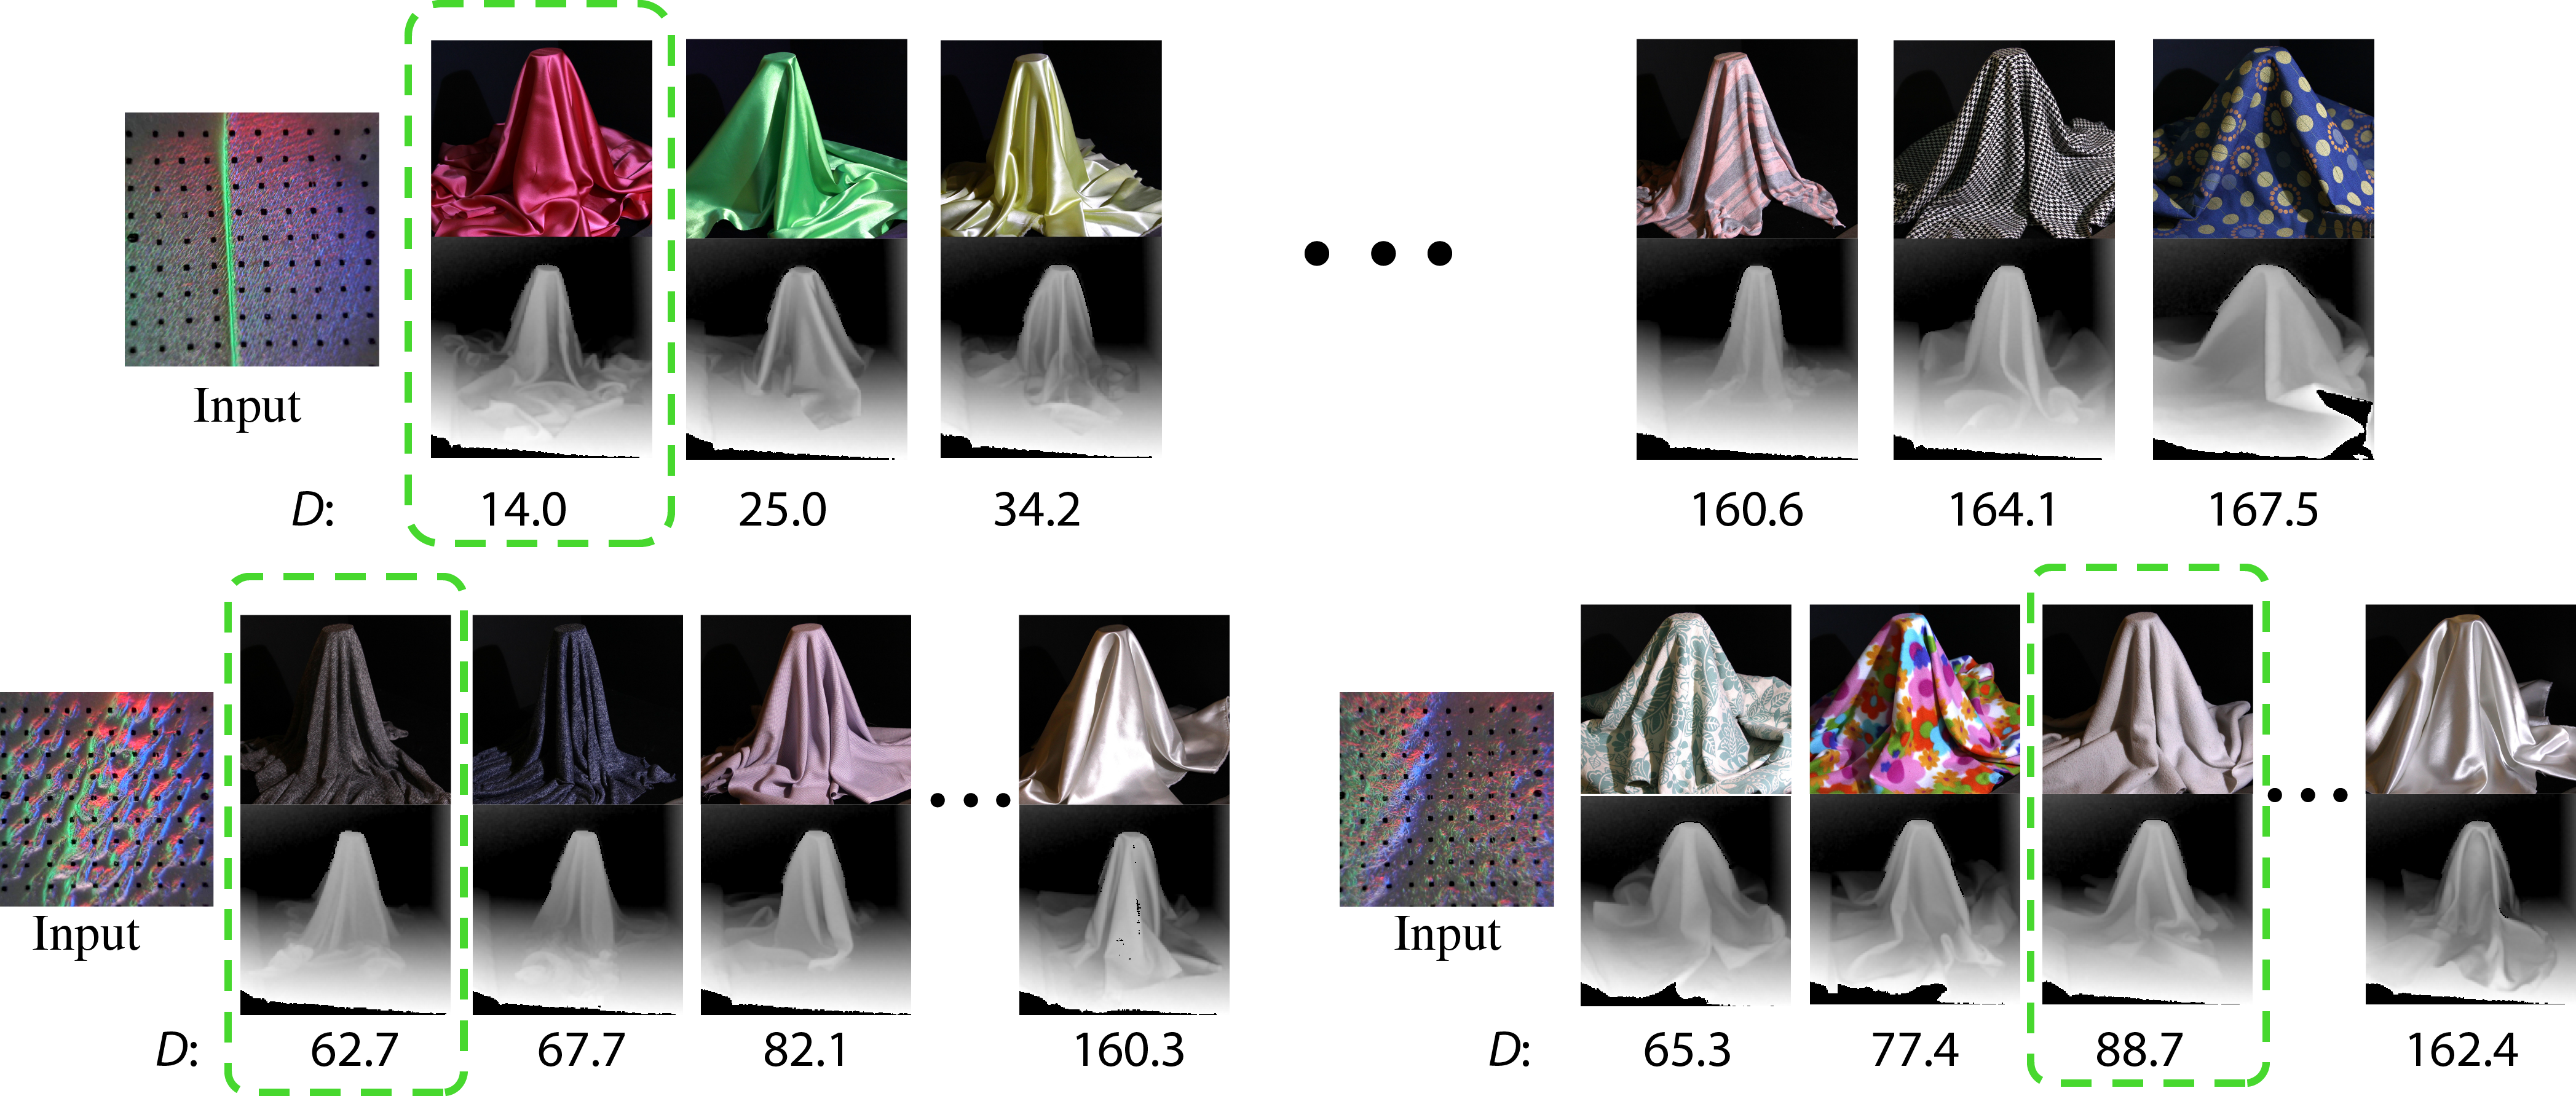
Connecting Look and Feel Connecting Look and Feel: Associating the Visual and Tactile Properties of Physical Materials
Wenzhen Yuan*, Shaoxiong Wang*, Siyuan Dong, Edward H. Adelson
CVPR, 2017  (Oral)
project page / paper / data
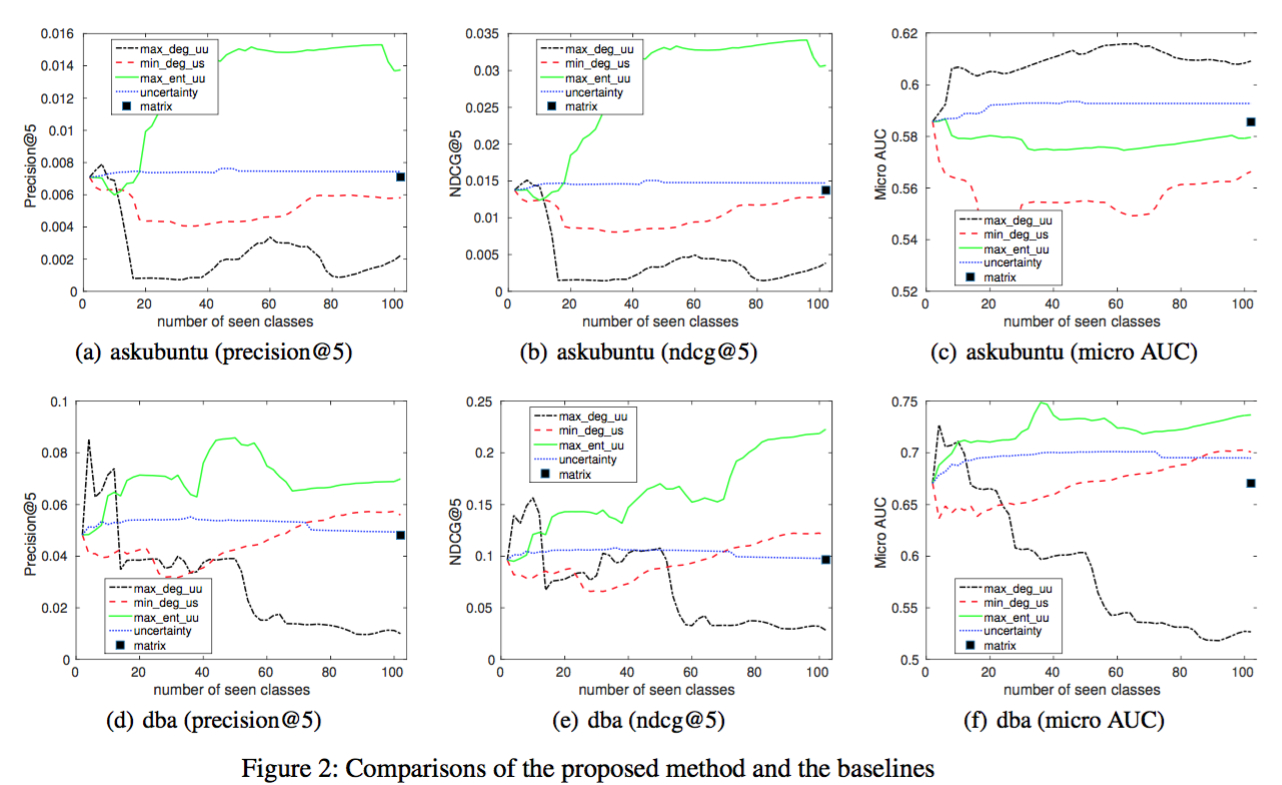
Active Zero-Shot Learning Active Zero-Shot Learning
Sihong Xie, Shaoxiong Wang, Philip S. Yu
CIKM, 2016
paper / data

Side Projects

How To Make (Almost) Anything MIT 6.943[J] How To Make (Almost) Anything
video / website

Teleoperation with force feedback: an ATmega16U4 micro-controller with USB support via the LUFA library, Hall-effect sensors & magnets for force sensing, and a 3D-printed cable-driven robot hand (Yale OpenHand).

Music Generation Music Generation with Long Short-Term Memory
1st Place in Microsoft Campus Elite Program (news)
Grand Prize in 35th Tsinghua Challenge Cup, top 6 among 381 teams (news)

A comprehensive music generation system based on Long Short-Term Memory (LSTM) networks. It generates music automatically driven by data and is embedded with rich music knowledge.

Website template from Jon Barron.